Keyence · Cognex · SICK
Established camera systems for recognition, positioning and inspection.
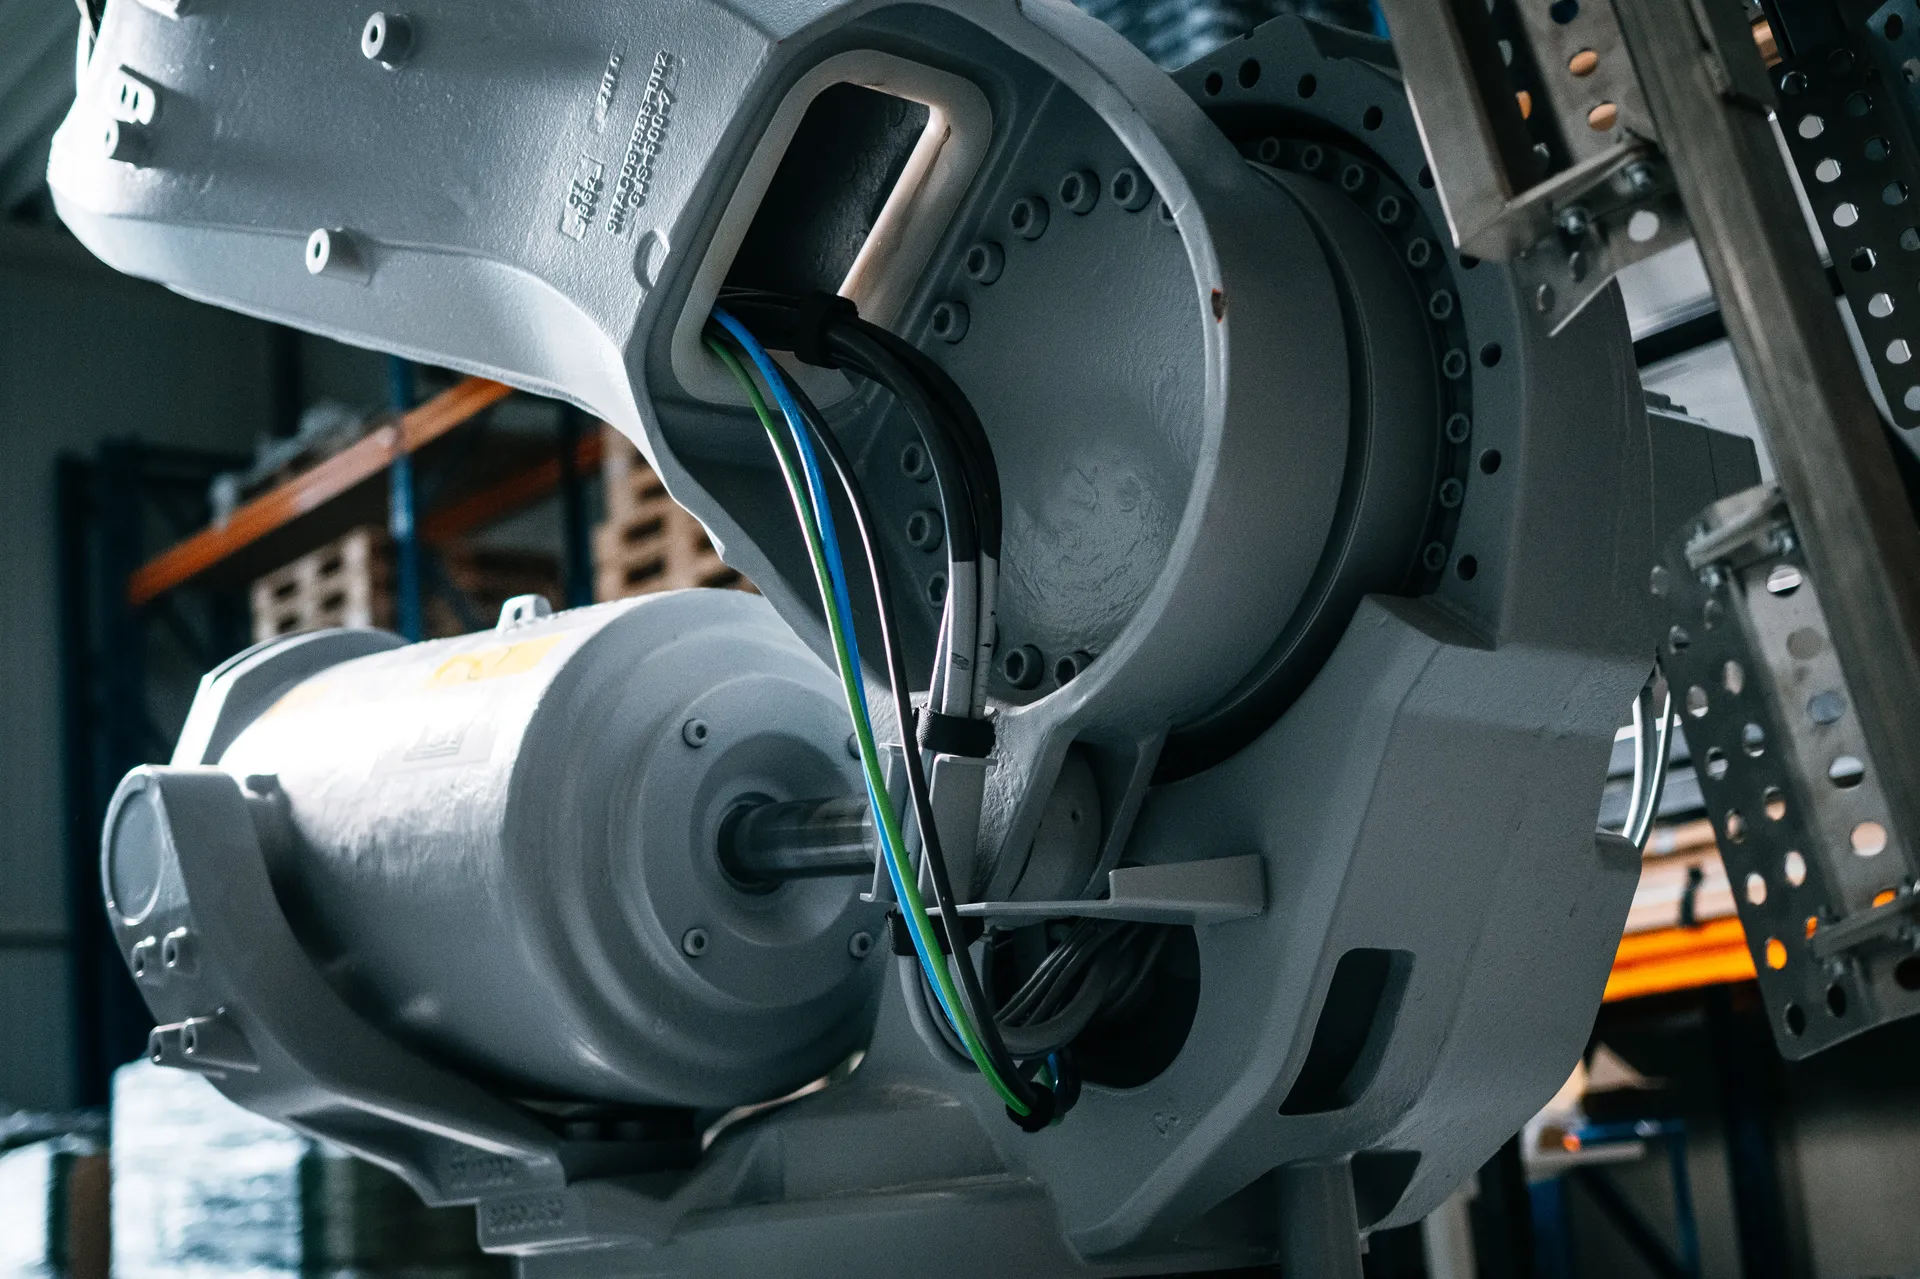
From palletising to inspection: we build the robot cell around your process. Brand-independent, with mechanics, control and vision working together.
We use virtual simulation to assess reach, payload, movements and expected cycle time. This helps us select a suitable robot type and model before developing the gripper, layout and robot cell design.
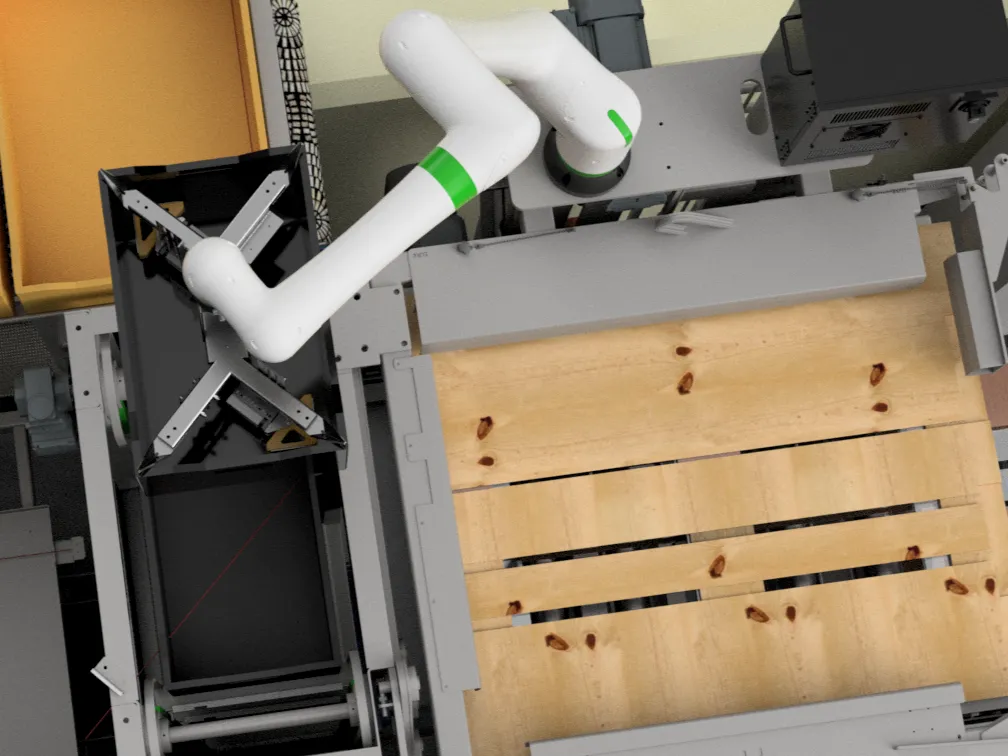
A smooth transition between your production line and the pallet. We integrate robots for cases, trays, bags and mixed pallets, matched to your infeed and outfeed.
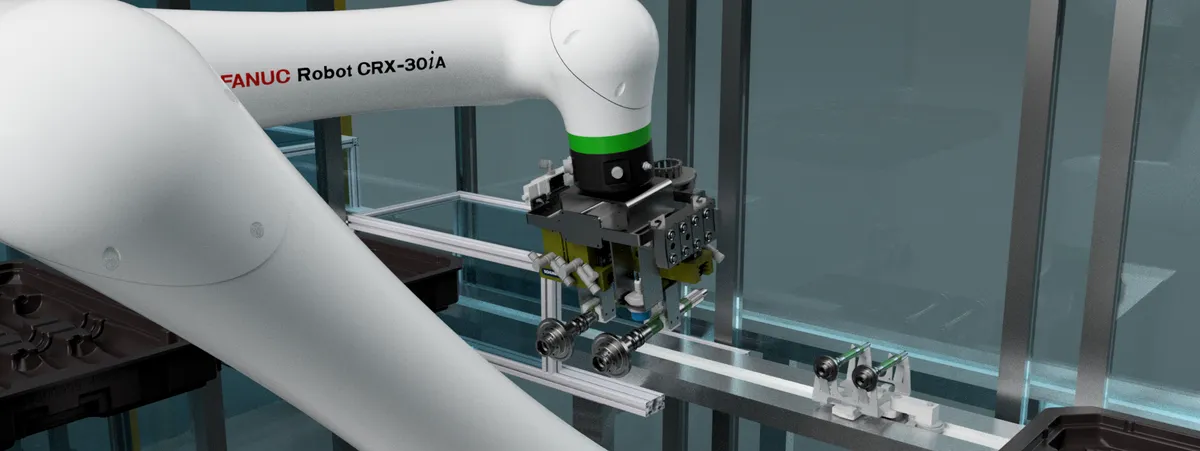
Your machine sets the pace. We make sure parts arrive at the right time and in the right position — including during unattended shifts.
An even coat depends on consistent motion. We match robot paths, tooling and workholding to the process.
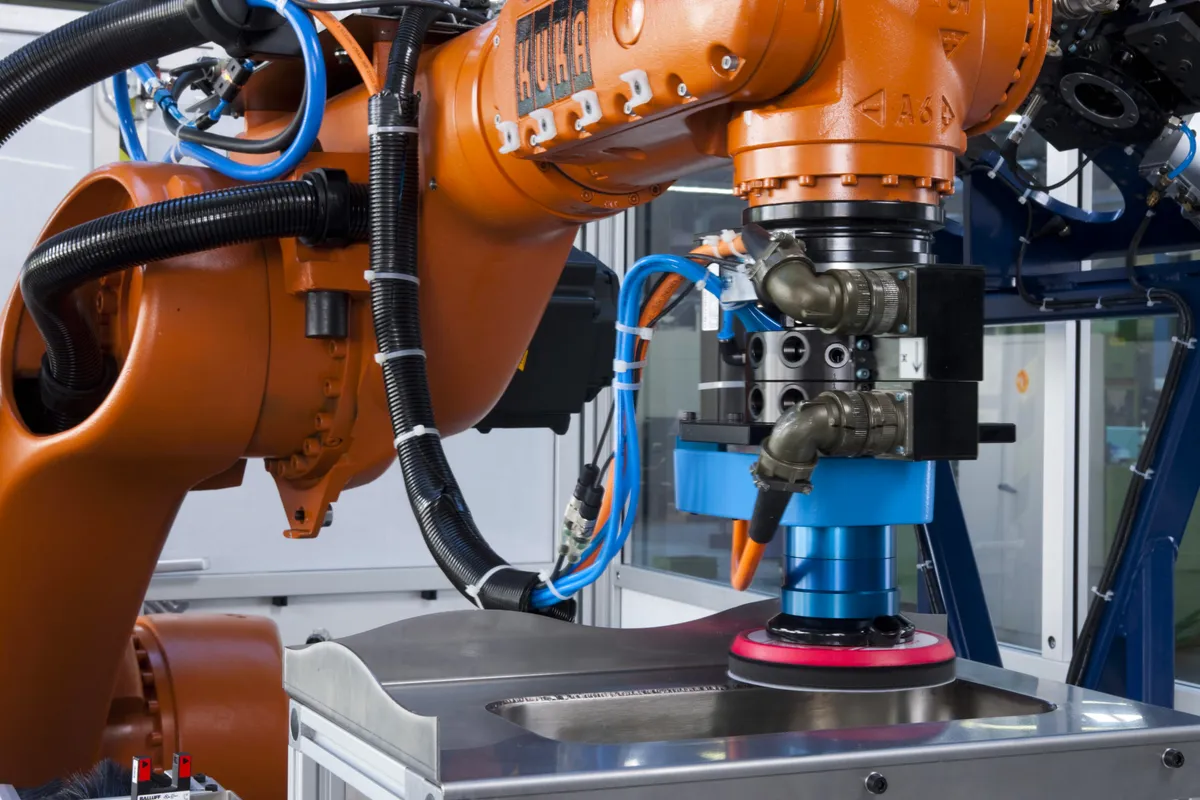
Consistent motion makes a difference at the surface. We match robot paths, tooling and workholding to the process.
Keep each part identifiable throughout the process. We integrate marking and engraving where traceability matters, including on curved surfaces.
Explore vision-guided gas cylinder engraving →
Discuss your application ↗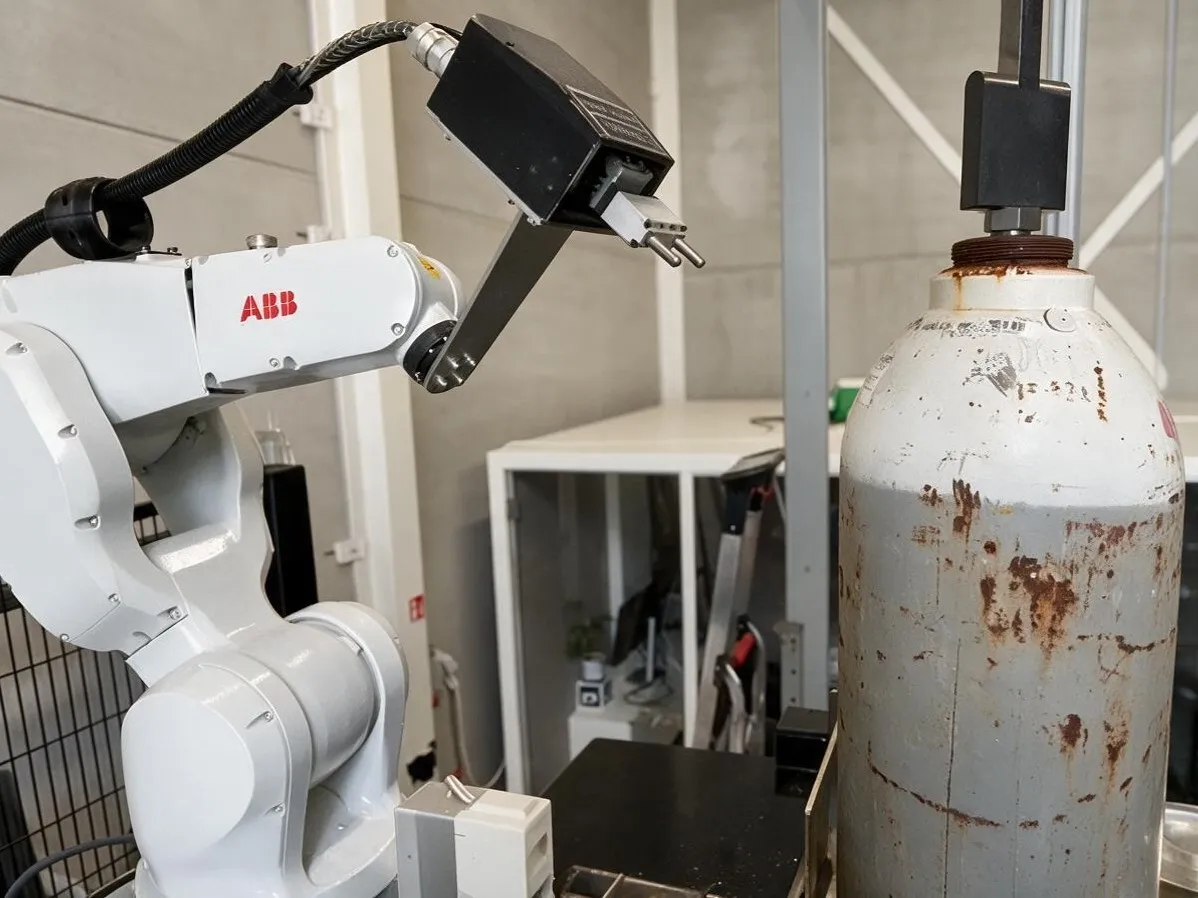
Unsorted parts do not have to mean an extra manual step. Vision, gripper design and robot control take them from bin to process.
Explore bin picking with 3D vision →
Discuss your application ↗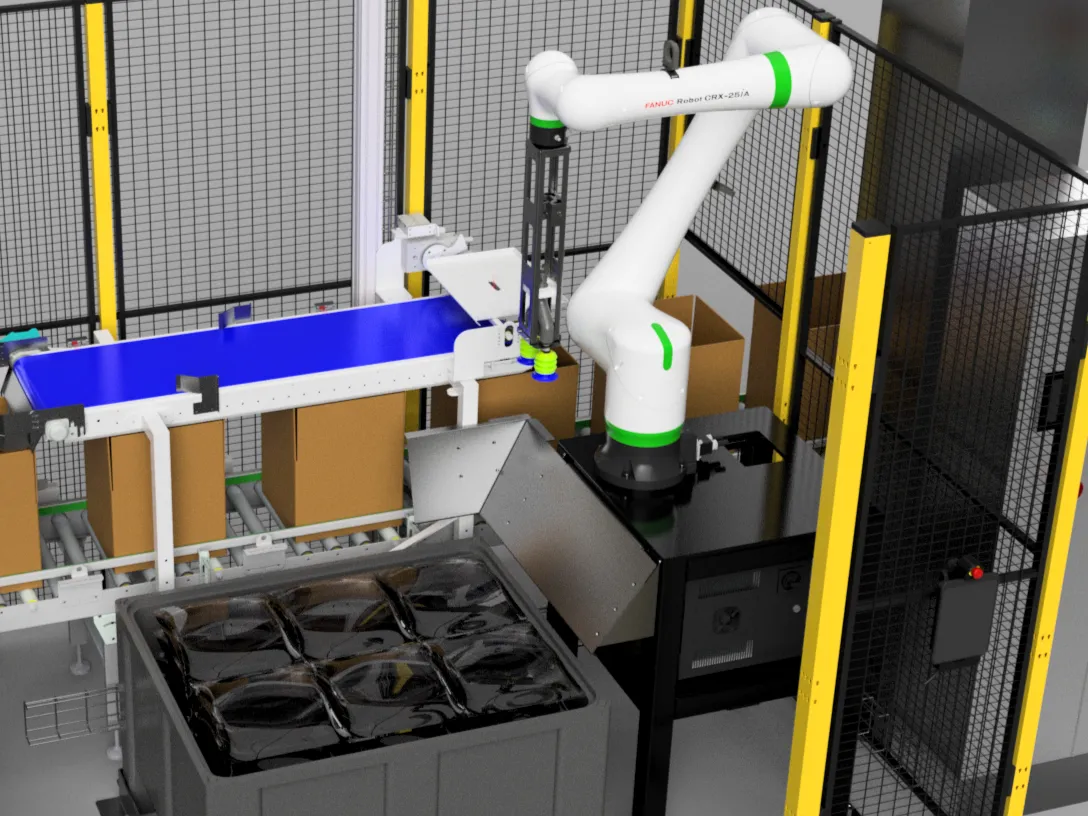
Inspection where it matters: in your line. We build visual and dimensional checks around your product and your quality criteria.
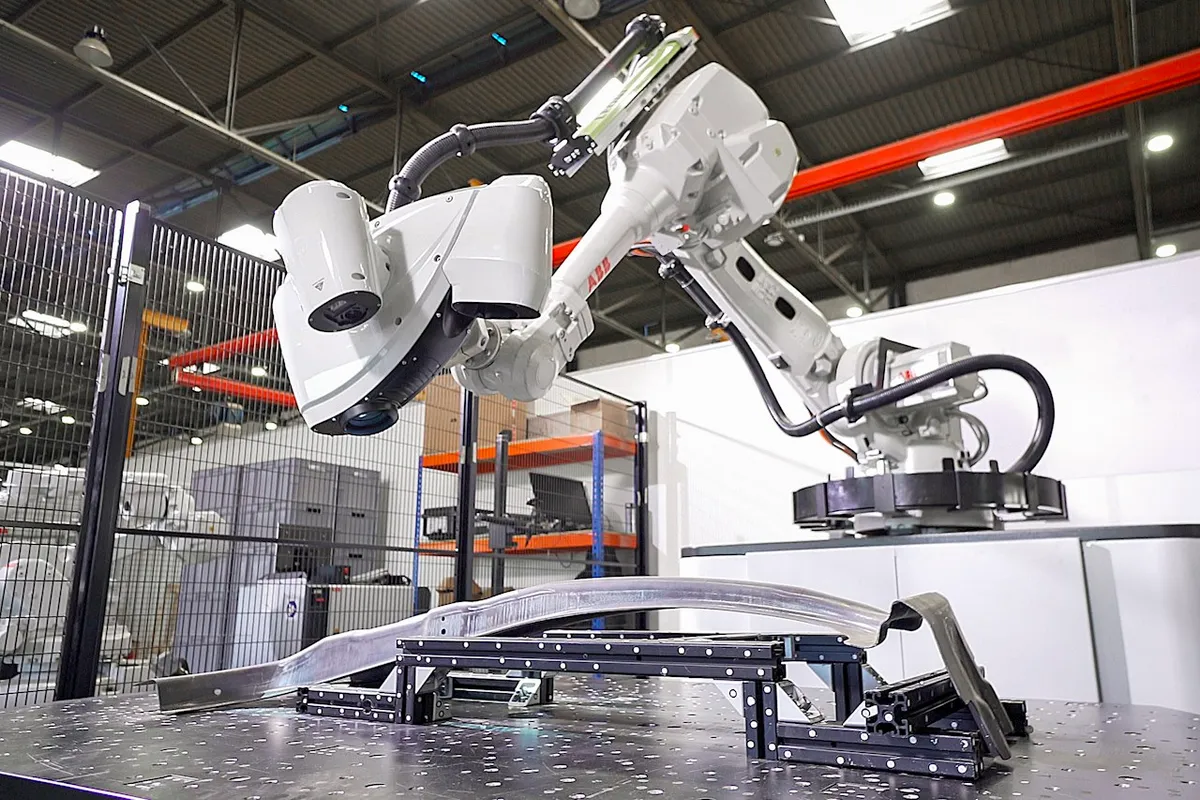
Apply adhesive where your product needs it. We match robot motion, the dispensing system and product positioning to your bonding process.
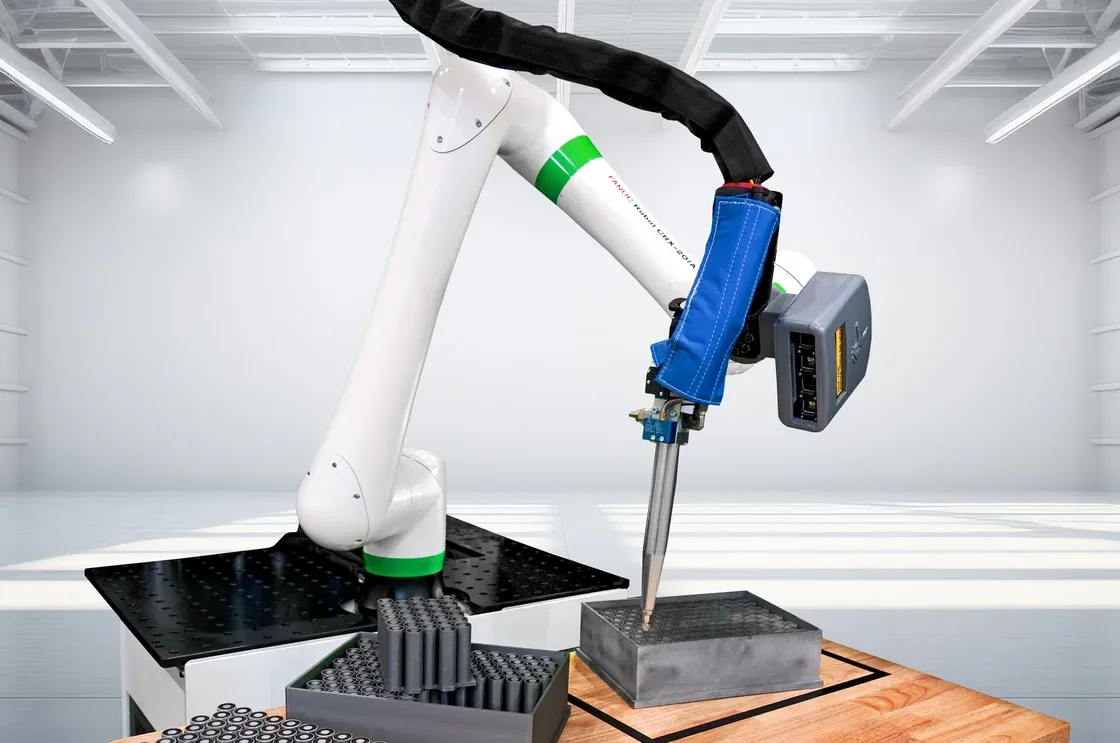
From locating parts to finding an empty area for engraving: we select the vision system based on your product, the task and the required accuracy.
Established camera systems for recognition, positioning and inspection.
3D recognition for picking products that vary in position.
With specialist vision partners, we tailor image processing to your product and criteria. For example, finding an empty area on a gas cylinder and sending the engraving position to the robot.
Explore the engraving applicationA specific challenge or an early idea? Let’s talk it through.